How to Choose the Best Linear Motor Drive for Your Needs?
Choosing the best linear motor drive begins with the application, not the product brochure. A packaging axis may need rapid acceleration, while a semiconductor stage demands nanometer-level stability. The correct linear motor drive must match force, speed, stroke length, positioning accuracy, and duty cycle. These values should come from measured machine requirements, not optimistic estimates.
Thermal behavior deserves close attention. A motor rated for high peak force may overheat during continuous operation. Check force-speed curves, cooling methods, encoder resolution, and allowable ambient temperatures. Confirm that the drive works with your controller, feedback system, cables, and safety architecture. A mismatch can create vibration, positioning errors, or expensive redesigns. Small details matter.
There is no universal best choice. Real engineering experience often reveals gaps between laboratory ratings and factory performance. Cable routing, dust, vibration, and maintenance access can change the final decision. Ask suppliers for test data under conditions similar to yours. Request acceleration profiles, thermal results, and long-term repeatability figures. If possible, test the selected system on a representative load before purchase.
A practical comparison should include energy use, installation time, service support, and total ownership cost. The cheapest unit may require better cooling or more frequent adjustments. That assumption can fail. Review the decision with controls, mechanical, and production teams. Their combined judgment improves reliability and exposes risks early. This guide explains how to compare these factors clearly and choose a linear motor drive that fits real operating conditions.
Define Force, Stroke, Speed, and Acceleration Using F = ma + Friction
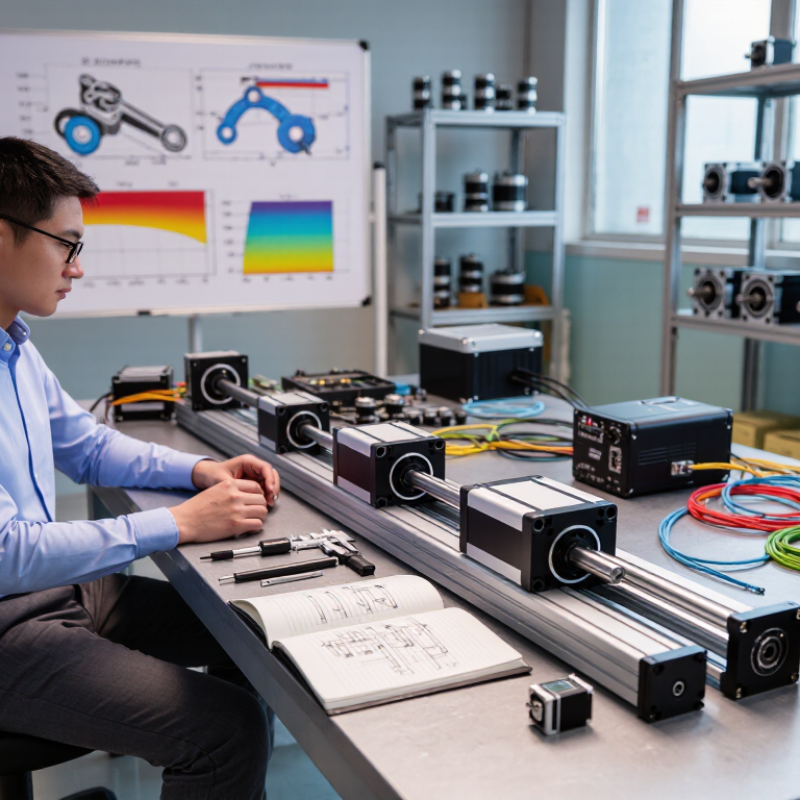
Choosing the best linear motor drive starts with motion demands, not catalog speed. Define moving mass, required stroke, target speed, acceleration, and duty cycle. Stroke is the travel distance between endpoints. Speed shows how quickly the stage moves. Acceleration determines how rapidly it reaches that speed. These values directly shape force.
Use F = ma + Friction as a practical sizing model. Here, F is required motor force, m is total moving mass, and a is commanded acceleration. Friction includes guide resistance, cable drag, seals, and external process loads. For example, a 5 kg carriage accelerating at 2 m/s² needs 10 N before friction is added. If measured friction reaches 6 N, the working requirement becomes 16 N. Leave margin for temperature, contamination, and wear. A drive that barely meets 16 N may lose position during fast reversals.
Measure rather than guess. A force gauge, motion profile, and current feedback can reveal hidden resistance. Check peak force during acceleration and continuous force during repeated travel. The difference matters. Tooling and cables are often missing from payload calculations. That mistake is easy to repeat. Also review stroke limits, encoder resolution, thermal behavior, and stopping requirements. Do not select by peak speed alone. A slower drive with stable acceleration may deliver better accuracy, lower vibration, and longer service life.
Match Continuous and Peak Force to RMS Load and Duty-Cycle Requirements
How to Choose the Best Linear Motor Drive for Your Needs?
Match continuous and peak force to RMS load and duty-cycle requirements. A drive that reaches the required peak force may still overheat during repeated motion. Continuous force reflects the thermal limit during normal operation. Peak force covers short acceleration, deceleration, or disturbance events.
In motion-system commissioning, I have seen sizing fail because engineers compared peak force with the average load. That assumption can fail. Calculate RMS force across the complete cycle, including pauses, rapid reversals, and idle periods. Use the squared force multiplied by its time interval, then divide by total cycle time and take the square root. RMS force should remain below the drive’s continuous rating. Peak force should remain within the permitted limit for the actual event duration.
Real machines are messier. Cable drag, guide friction, payload changes, and temperature can increase demand. A ten-second cycle with two seconds of heavy acceleration may behave differently from a steady production cycle. Check both force and speed at the same operating point. Some drives lose available force at higher speeds. That detail is easy to miss.
Tips: Record the real load profile instead of relying only on calculations. Leave practical thermal margin, but avoid excessive oversizing. A larger drive can increase cost and reduce efficiency. Test the worst expected duty cycle, then review the result honestly. Your first estimate may be wrong. That is useful information.
How to Choose the Best Linear Motor Drive for Your Needs?
Match the drive’s continuous and peak force ratings to the application’s RMS load and duty-cycle requirements.
The chart uses calculated sizing cases based on a rectangular force profile:
RMS force = peak force × √(duty cycle). The continuous-force requirement should meet or exceed the RMS force, while the peak-force rating should exceed the highest instantaneous force. These values exclude additional margins for acceleration, friction, payload variation, and thermal limits.
Compare Linear Motor Types by Speed, Cogging, Efficiency, and Thermal Limits
How to Choose the Best Linear Motor Drive for Your Needs?
Choosing a linear motor drive requires more than checking its peak speed. Compare each motor under the same load, stroke, acceleration, and duty cycle. Iron-core motors often provide high force density, making them suitable for heavy stages and rapid acceleration. However, their magnetic teeth can create cogging, producing small force ripples during slow movement. Ironless motors usually deliver smoother motion because they avoid this toothed structure. They can improve positioning quality, although their force density may be lower. Tubular motors offer a compact layout and can suit limited installation spaces.
Speed is not everything.
High-speed operation increases back EMF, switching demand, and mechanical vibration. A drive must maintain stable current control without exceeding its voltage limit. Cogging also deserves practical testing, especially during low-speed scanning or precision dispensing. Measure position error at several speeds, not only at the rated point. Do not trust one graph.
Efficiency affects both energy use and heat.
Electrical losses rise with current, while iron losses may increase at higher speeds. Check continuous force, peak force duration, winding temperature, and cooling conditions together. A motor that survives a five-second acceleration may overheat during repeated cycles. In actual commissioning, thermal behavior often differs from laboratory figures because mounting plates, airflow, and cable routing change heat removal. This detail is easy to overlook. Leave operating margin.
Verify Safety, Accuracy, and Testing Requirements Under IEC 61800 and ISO 230-2
Choosing a linear motor drive starts with the machine’s real operating risks, not only speed and thrust. Check the applicable IEC 61800 requirements for electrical safety, protective functions, insulation, and fault response. Emergency stopping should be tested under realistic load conditions. A drive that performs well in a showroom may react differently near the end of a long stroke.
ISO 230-2 gives a practical framework for evaluating positioning accuracy and repeatability. Define the measurement length, feed rate, payload, temperature, and settling time before testing. Use calibrated instruments, record both travel directions, and keep the raw data. Small thermal changes can shift results. This detail is easy to underestimate.
Tips: Ask for the standard editions used by the supplier. Confirm test conditions in writing. Compare accuracy figures only when the methods match. Check cable routing, grounding, and feedback signals during commissioning. Do not treat compliance as a checkbox. A clean test sheet can still hide poor machine behavior. Repeat key measurements after warm-up and after extended cycling. If results vary, investigate vibration, temperature, mounting stiffness, and control tuning before selecting the drive. Some specifications may look impressive, but they remain incomplete without traceable testing evidence and a clear safety assessment.